RoboticsAdvanced
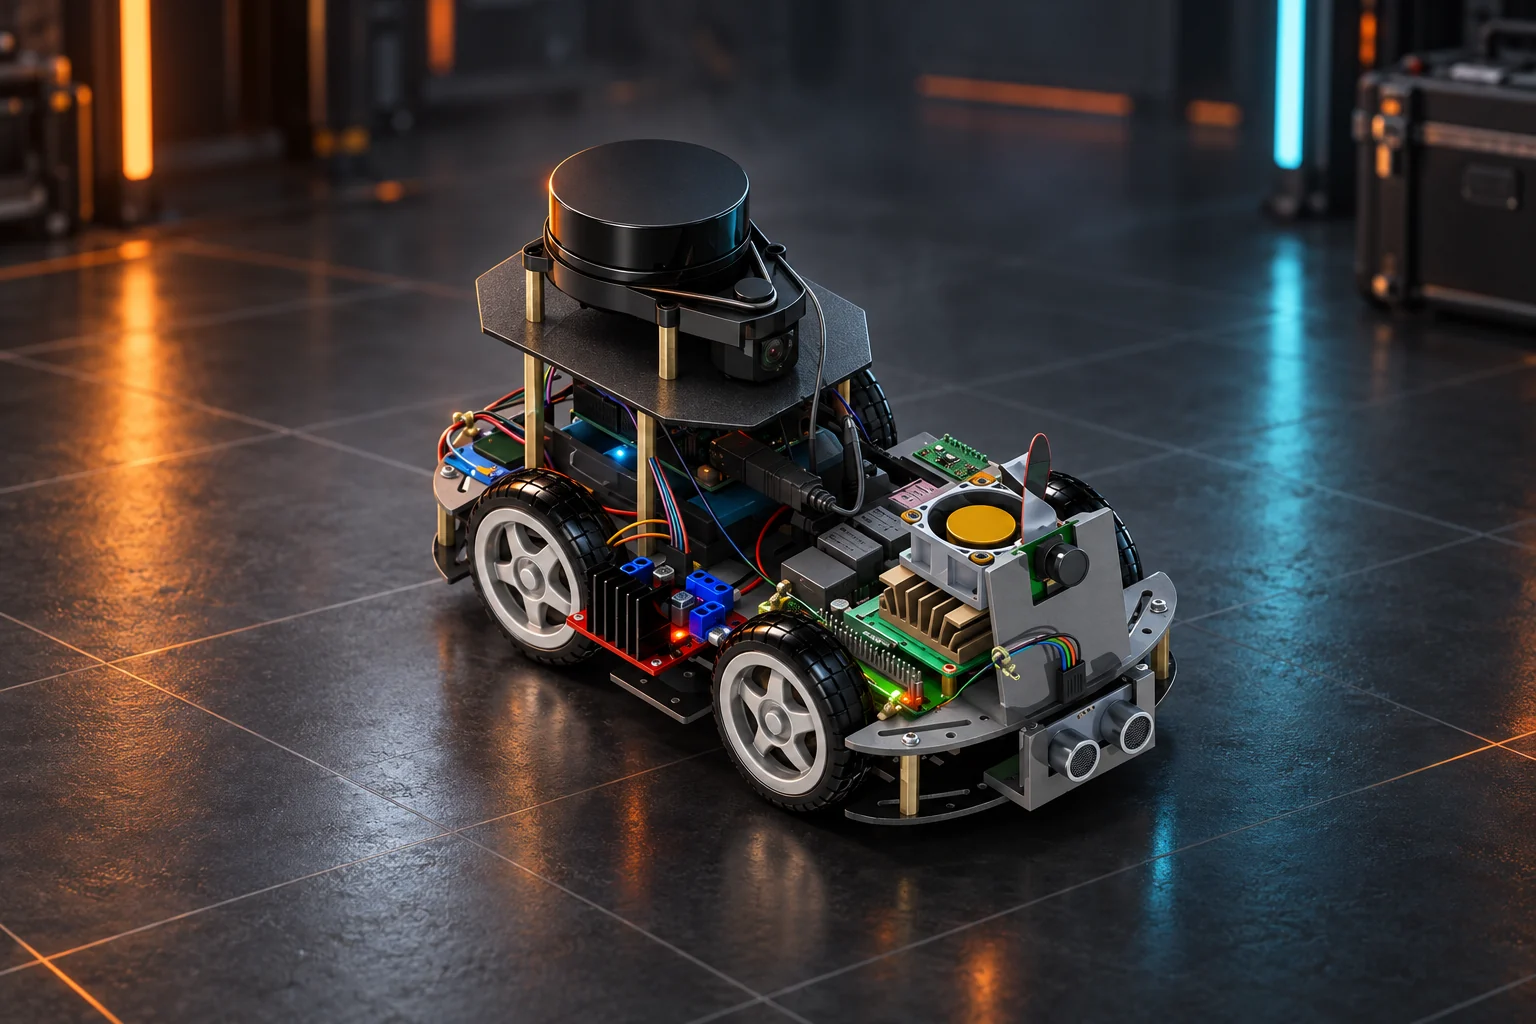
WildeBeest Pro
A complete dual-ROS autonomous-robot reference stack joining CAD, simulation, navigation, sensor fusion, a safety-oriented Arduino controller and an operator dashboard.
ROS 2 JazzyPythonC++Arduino
Explore migrated Academy4Tech prototypes and open-source systems. Missing facts stay marked as missing; repositories remain the technical source of truth.
A complete dual-ROS autonomous-robot reference stack joining CAD, simulation, navigation, sensor fusion, a safety-oriented Arduino controller and an operator dashboard.
An Arduino-based timed feeder concept with three configurable feeding times, an LCD and keypad input.
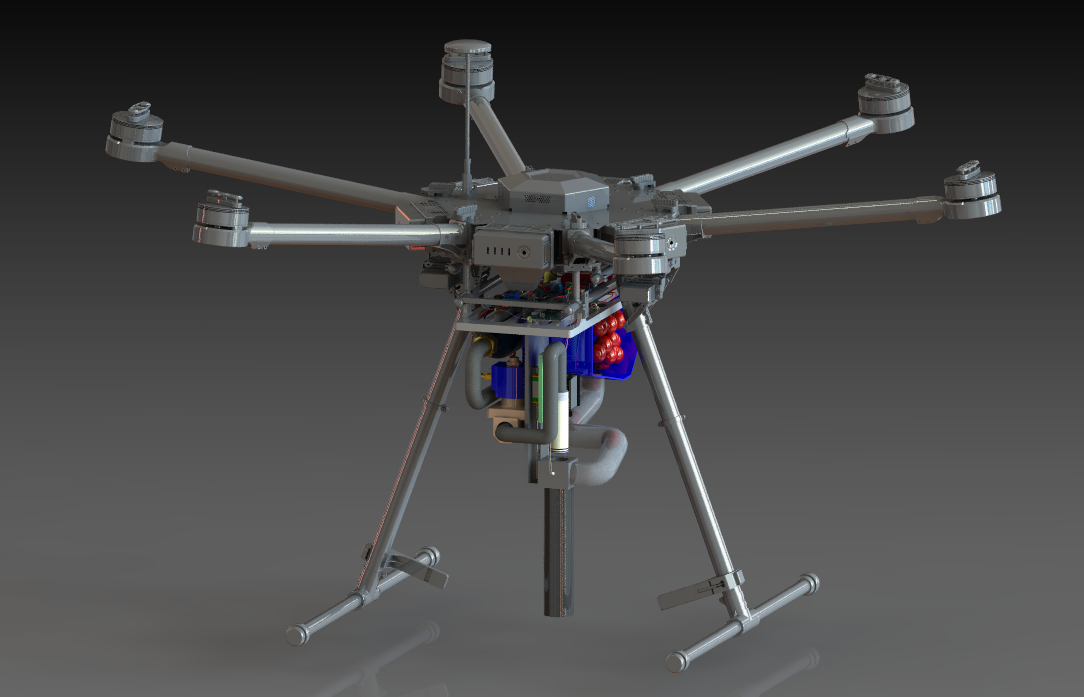
A concept and prototype for a DJI M600 Pro planting payload using a 3D-printed seed container and pneumatic firing mechanism.
Choose the right ESP32 board with an interactive family comparison, 13 student projects, official specifications, and a beginner-friendly custom-PCB schematic guide.
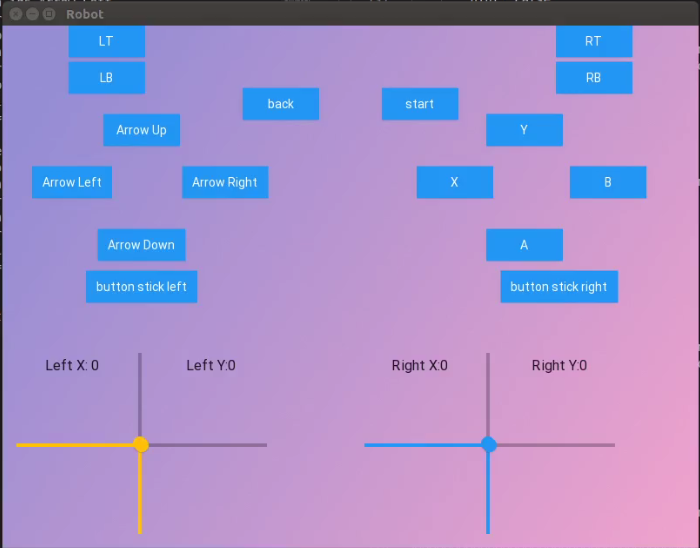
A Python and KivyMD interface that visualizes Logitech F710 joystick data carried through ROS.
No projects match those filters.